Sibaek Lee

Hi!😀 I am a PhD student in Intelligent Robotics at Sungkyunkwan University advised by Prof. Hyeonwoo yu where I am a member of the Lab of Artificial Intelligence and Robotics (Lair).
As a researcher, I hope my research contributes positively to society and I believe that artificial intelligence is a step towards achieving that goal. My research focuses on using deep learning techniques to enhance robots’ spatial perception. By improving their ability to perceive their environment accurately, we can enable robots to make better decisions, perform more complex tasks, and ultimately help people in various ways.
Research Interests
- 🧠 Deep Learning: 3D Vision, Vision Language Model, Generative model, Bayesian learning
- 🤖 Robotics: Simultaneous Localization and Mapping (SLAM), Robot Perception and navigation
News
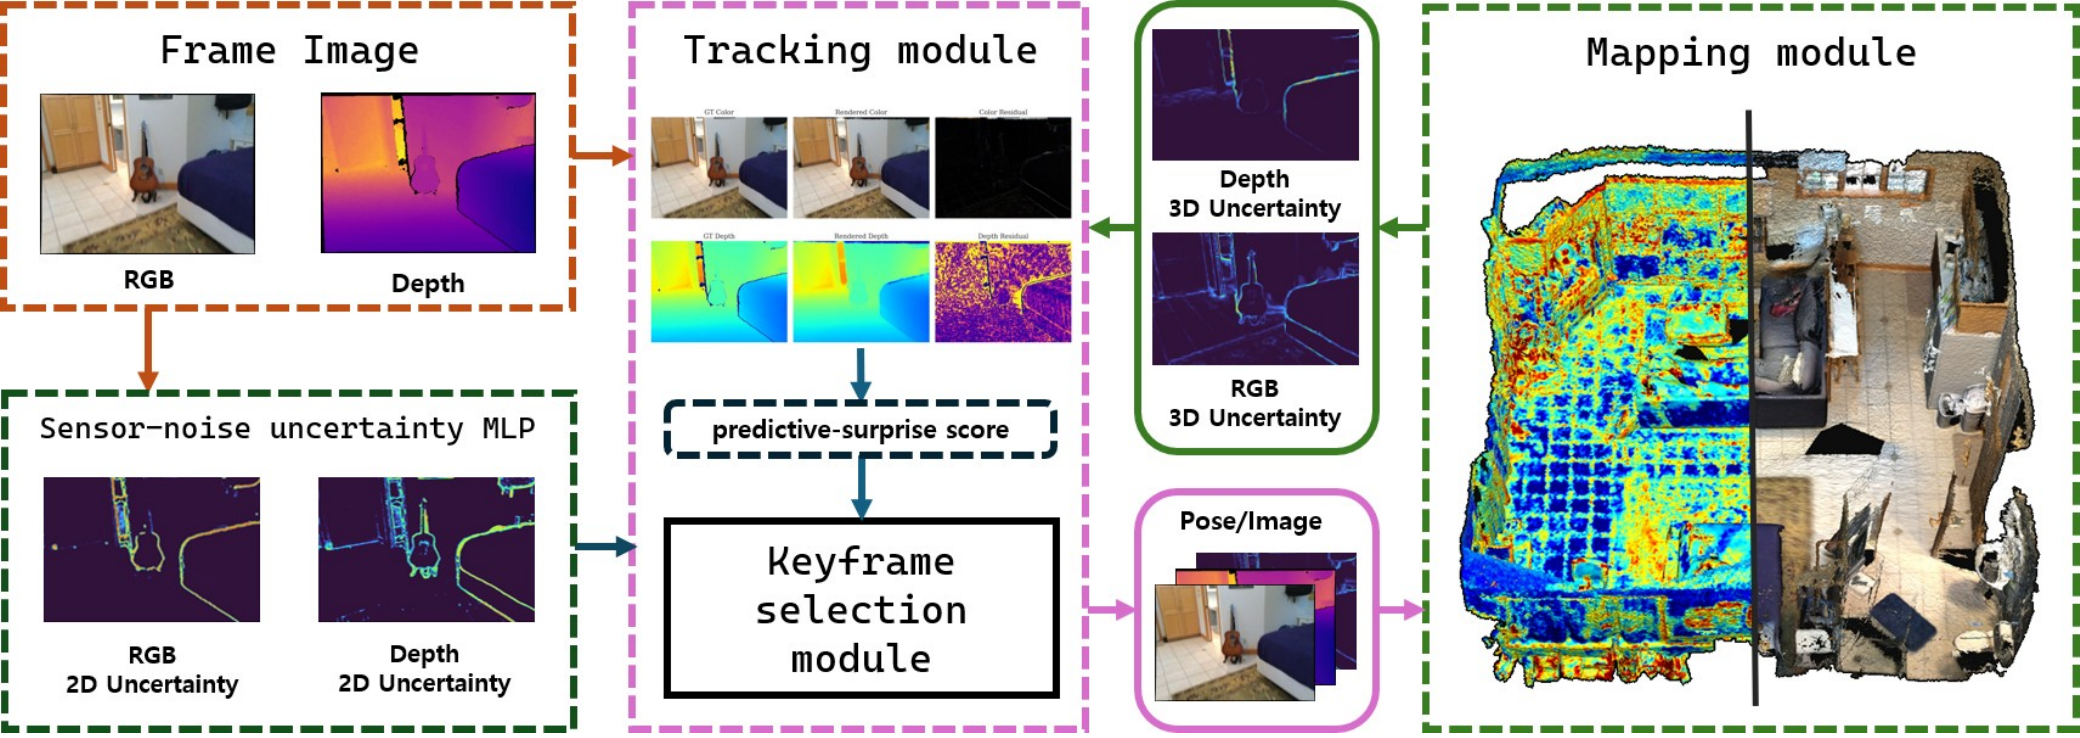
| Sep 2026 | 🎉 Our paper “BayesianGS-SLAM: Uncertainty-Aware Neural Rendering SLAM via Probabilistic Formulation” is accepted to RA-L 2026. |
|---|---|
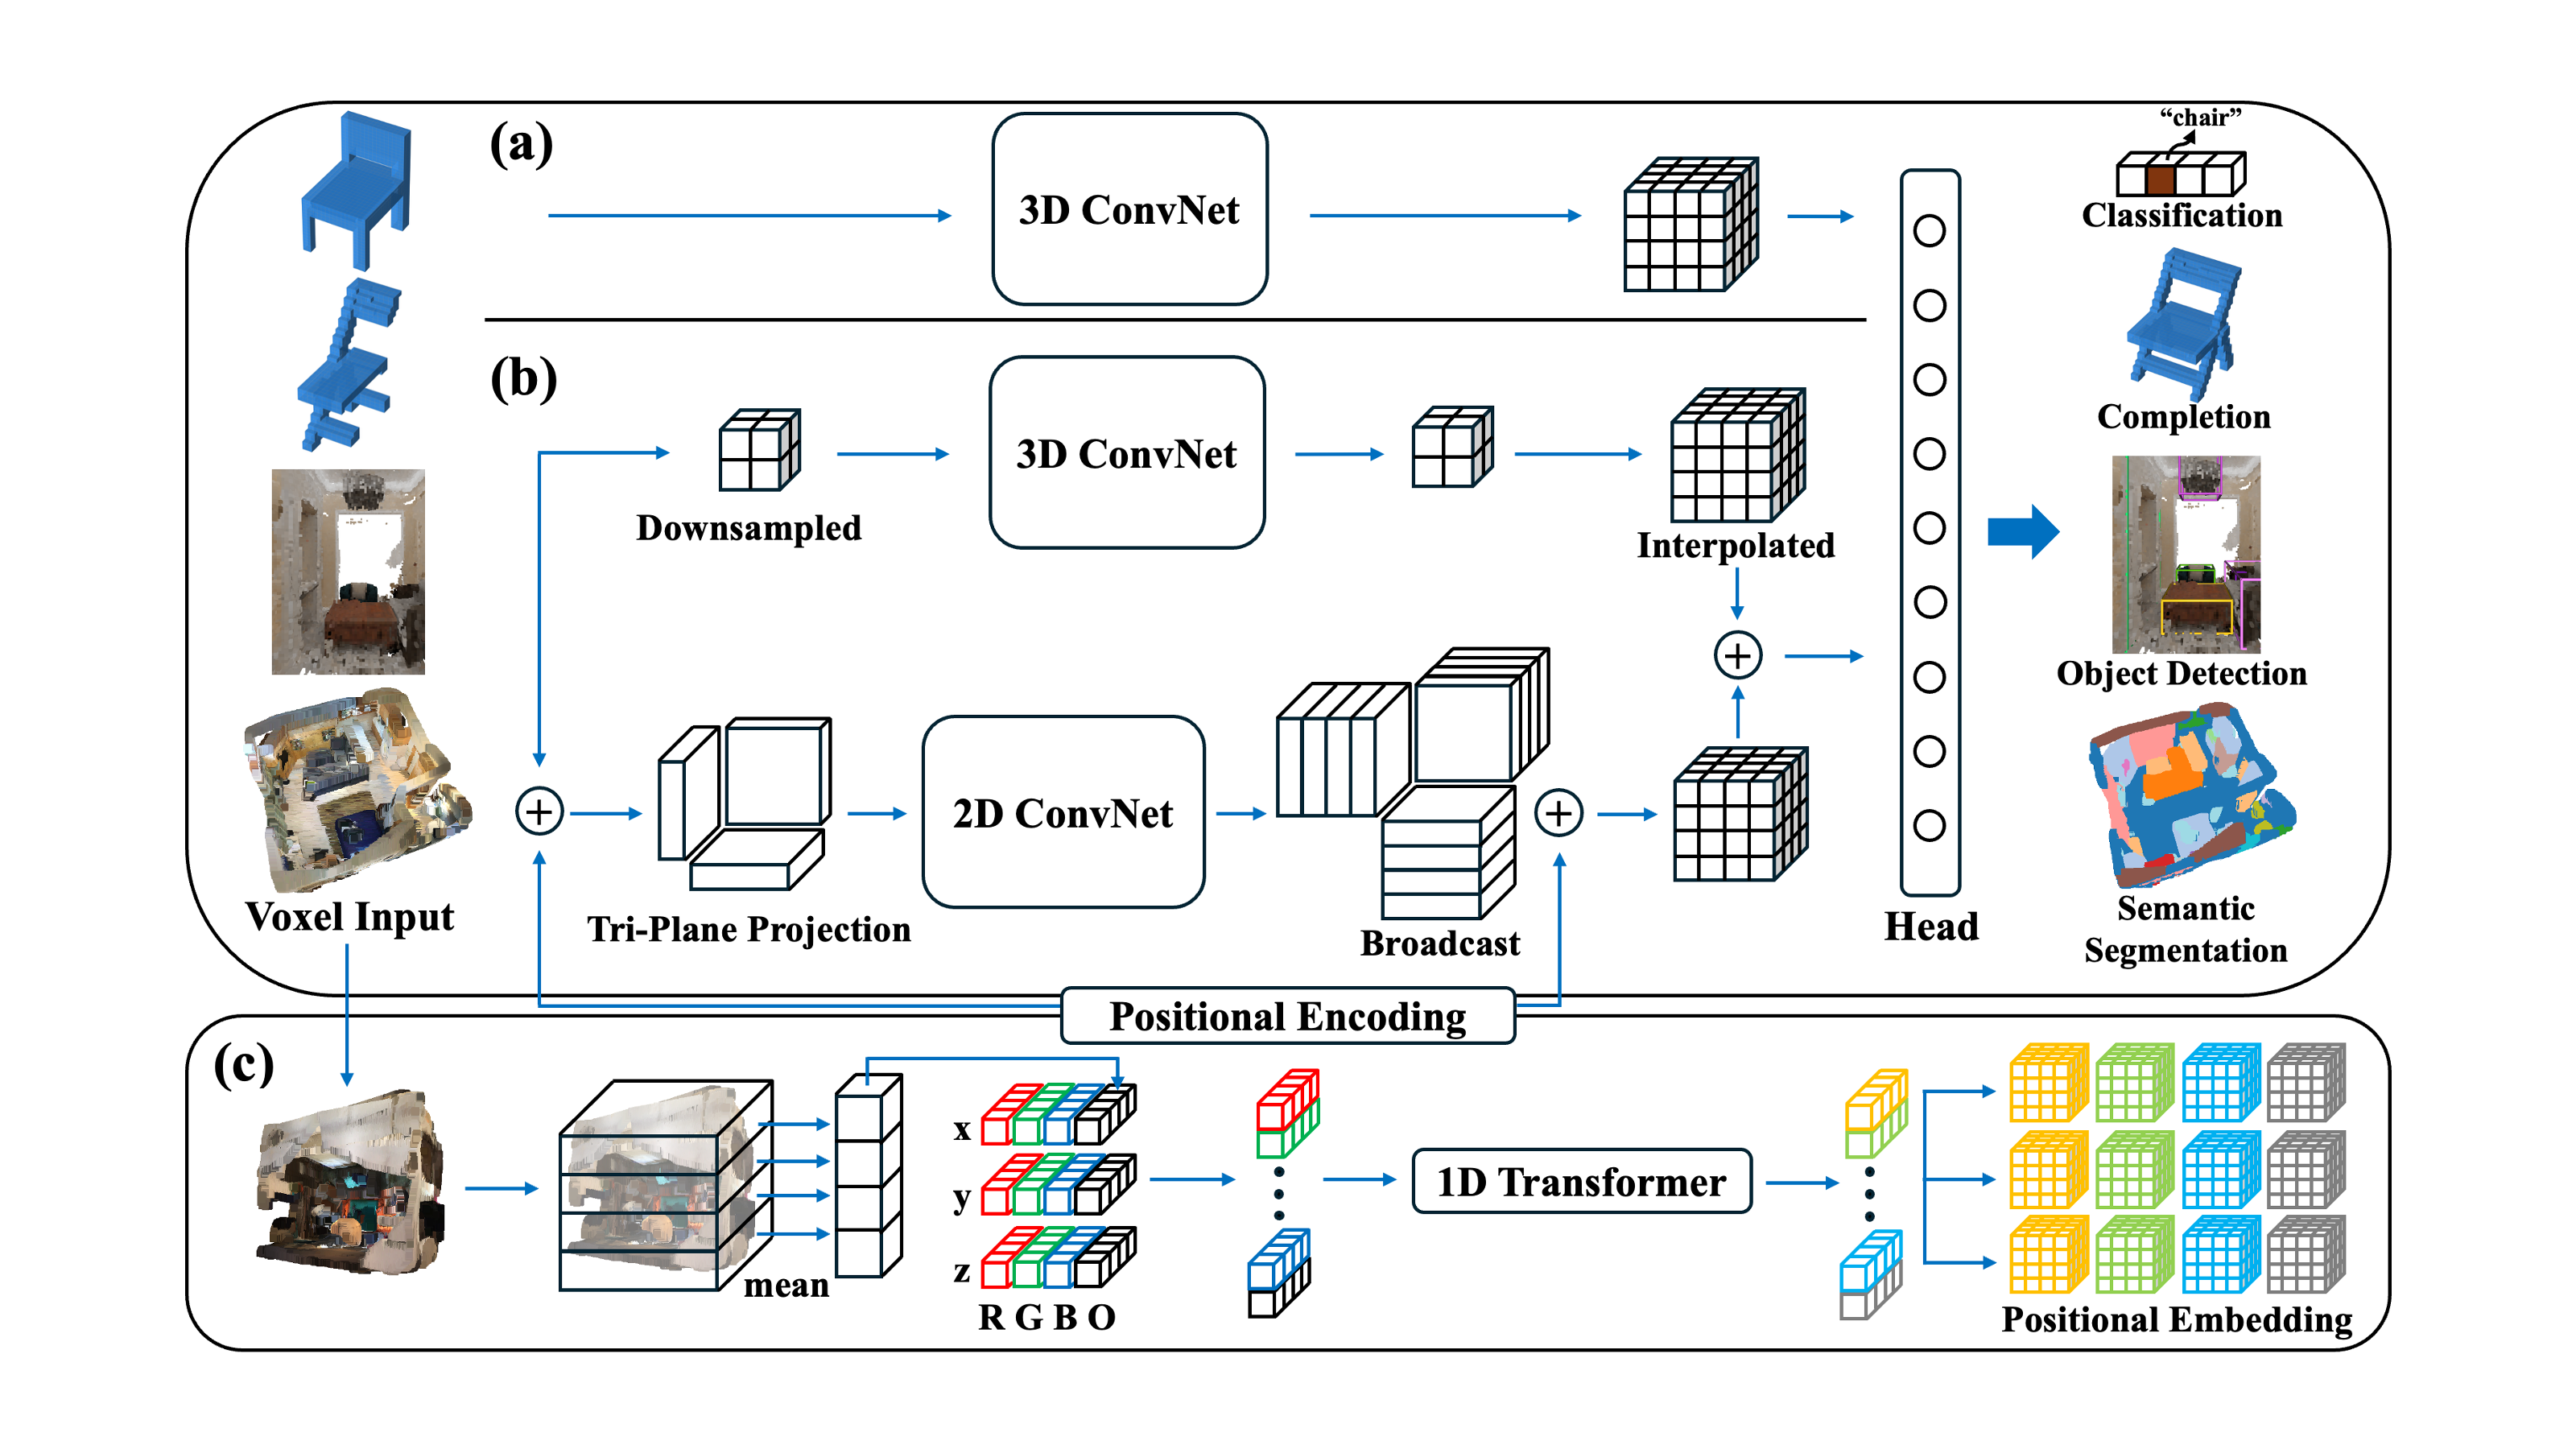
| Jun 2026 | 🎉 Our paper “TriLift: Interpolation-Free Tri-Plane Lifting for Efficient 3D Perception on Embedded Systems” is accepted to IROS 2026. |
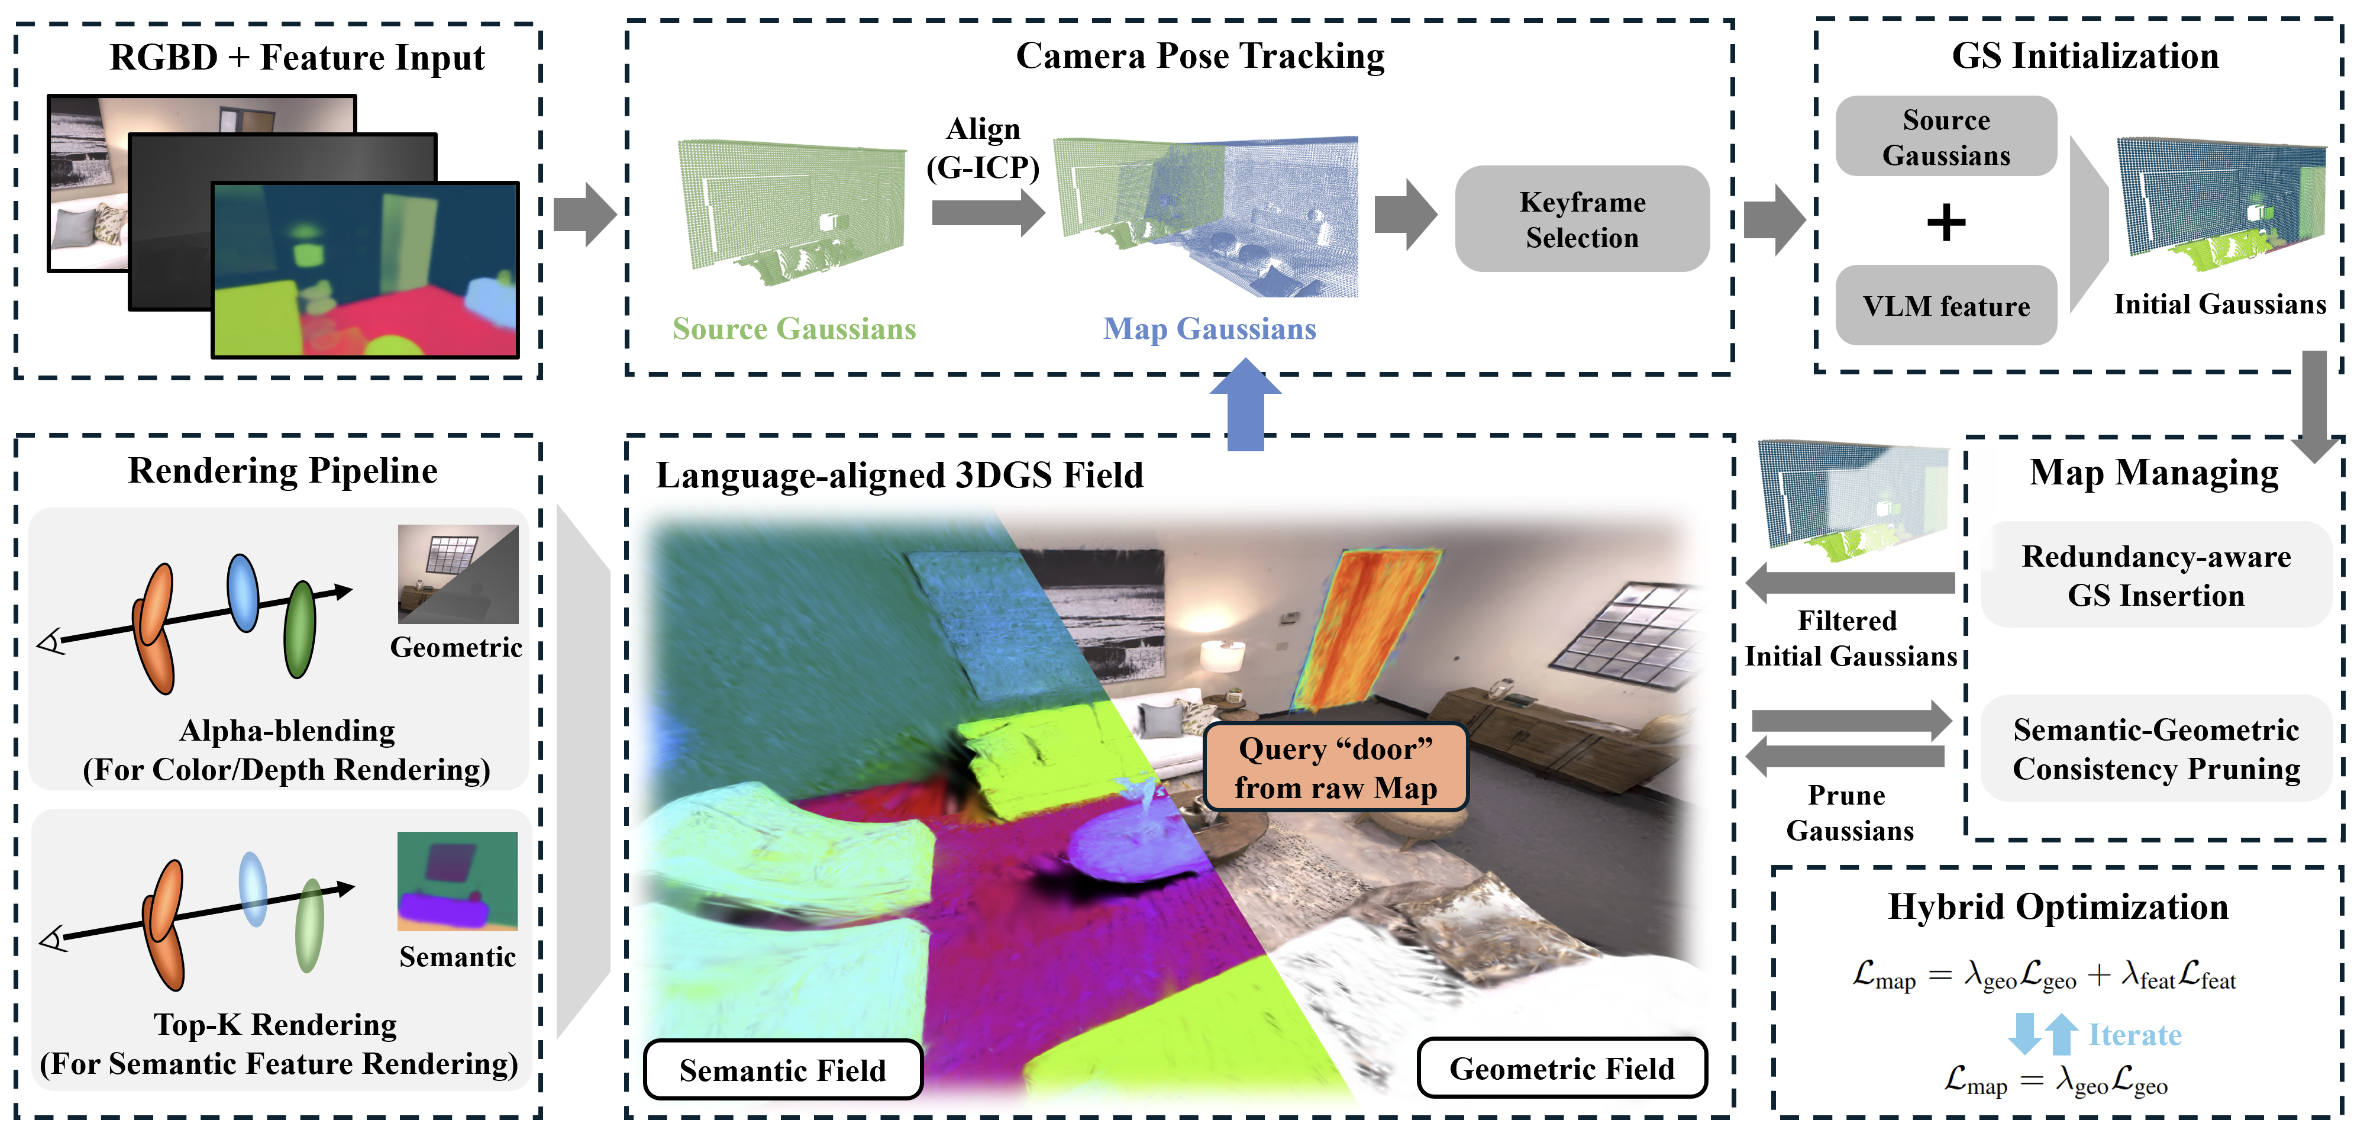
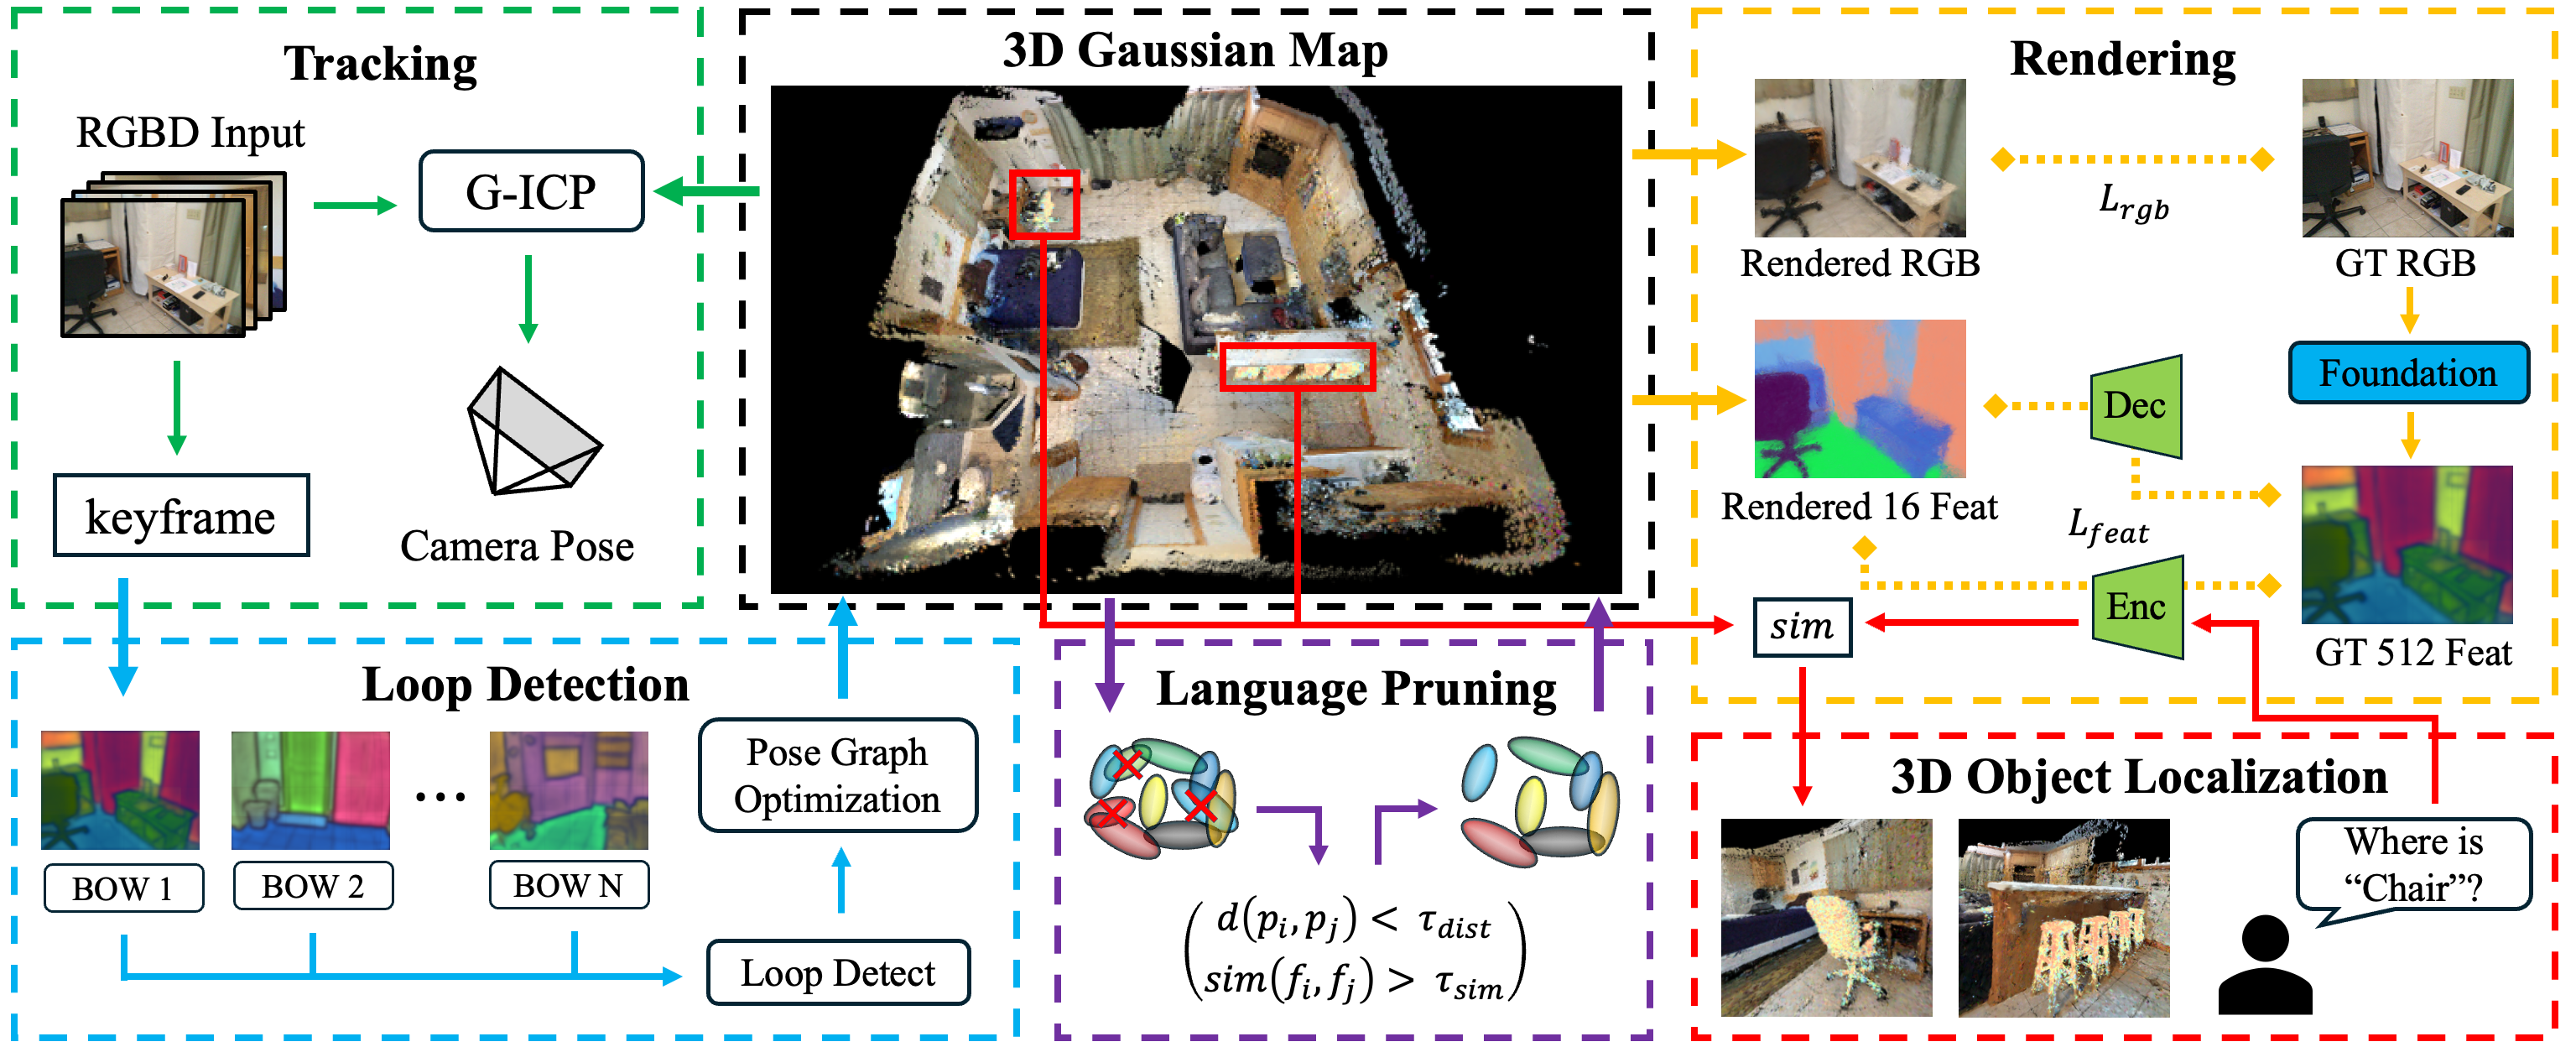
| Nov 2025 | 🎉 Our paper “LEGO-SLAM: Language-Embedded Gaussian Optimization SLAM” has been released on arXiv! |
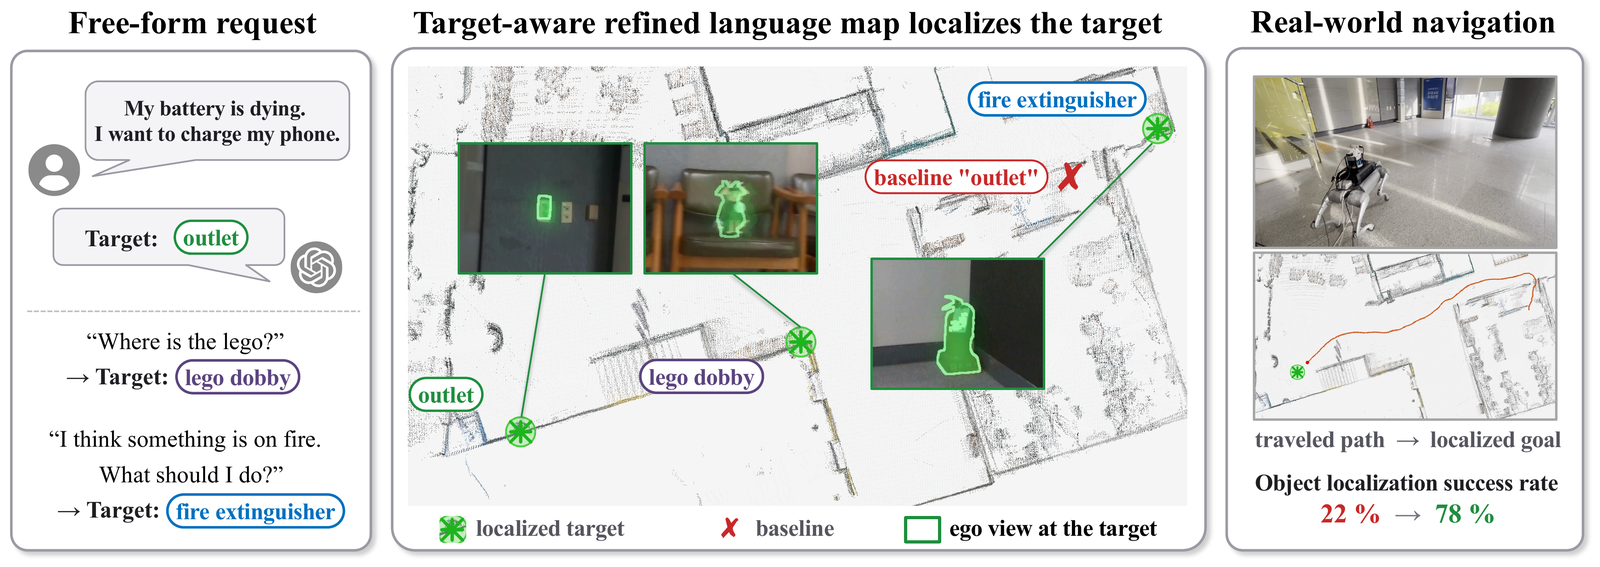
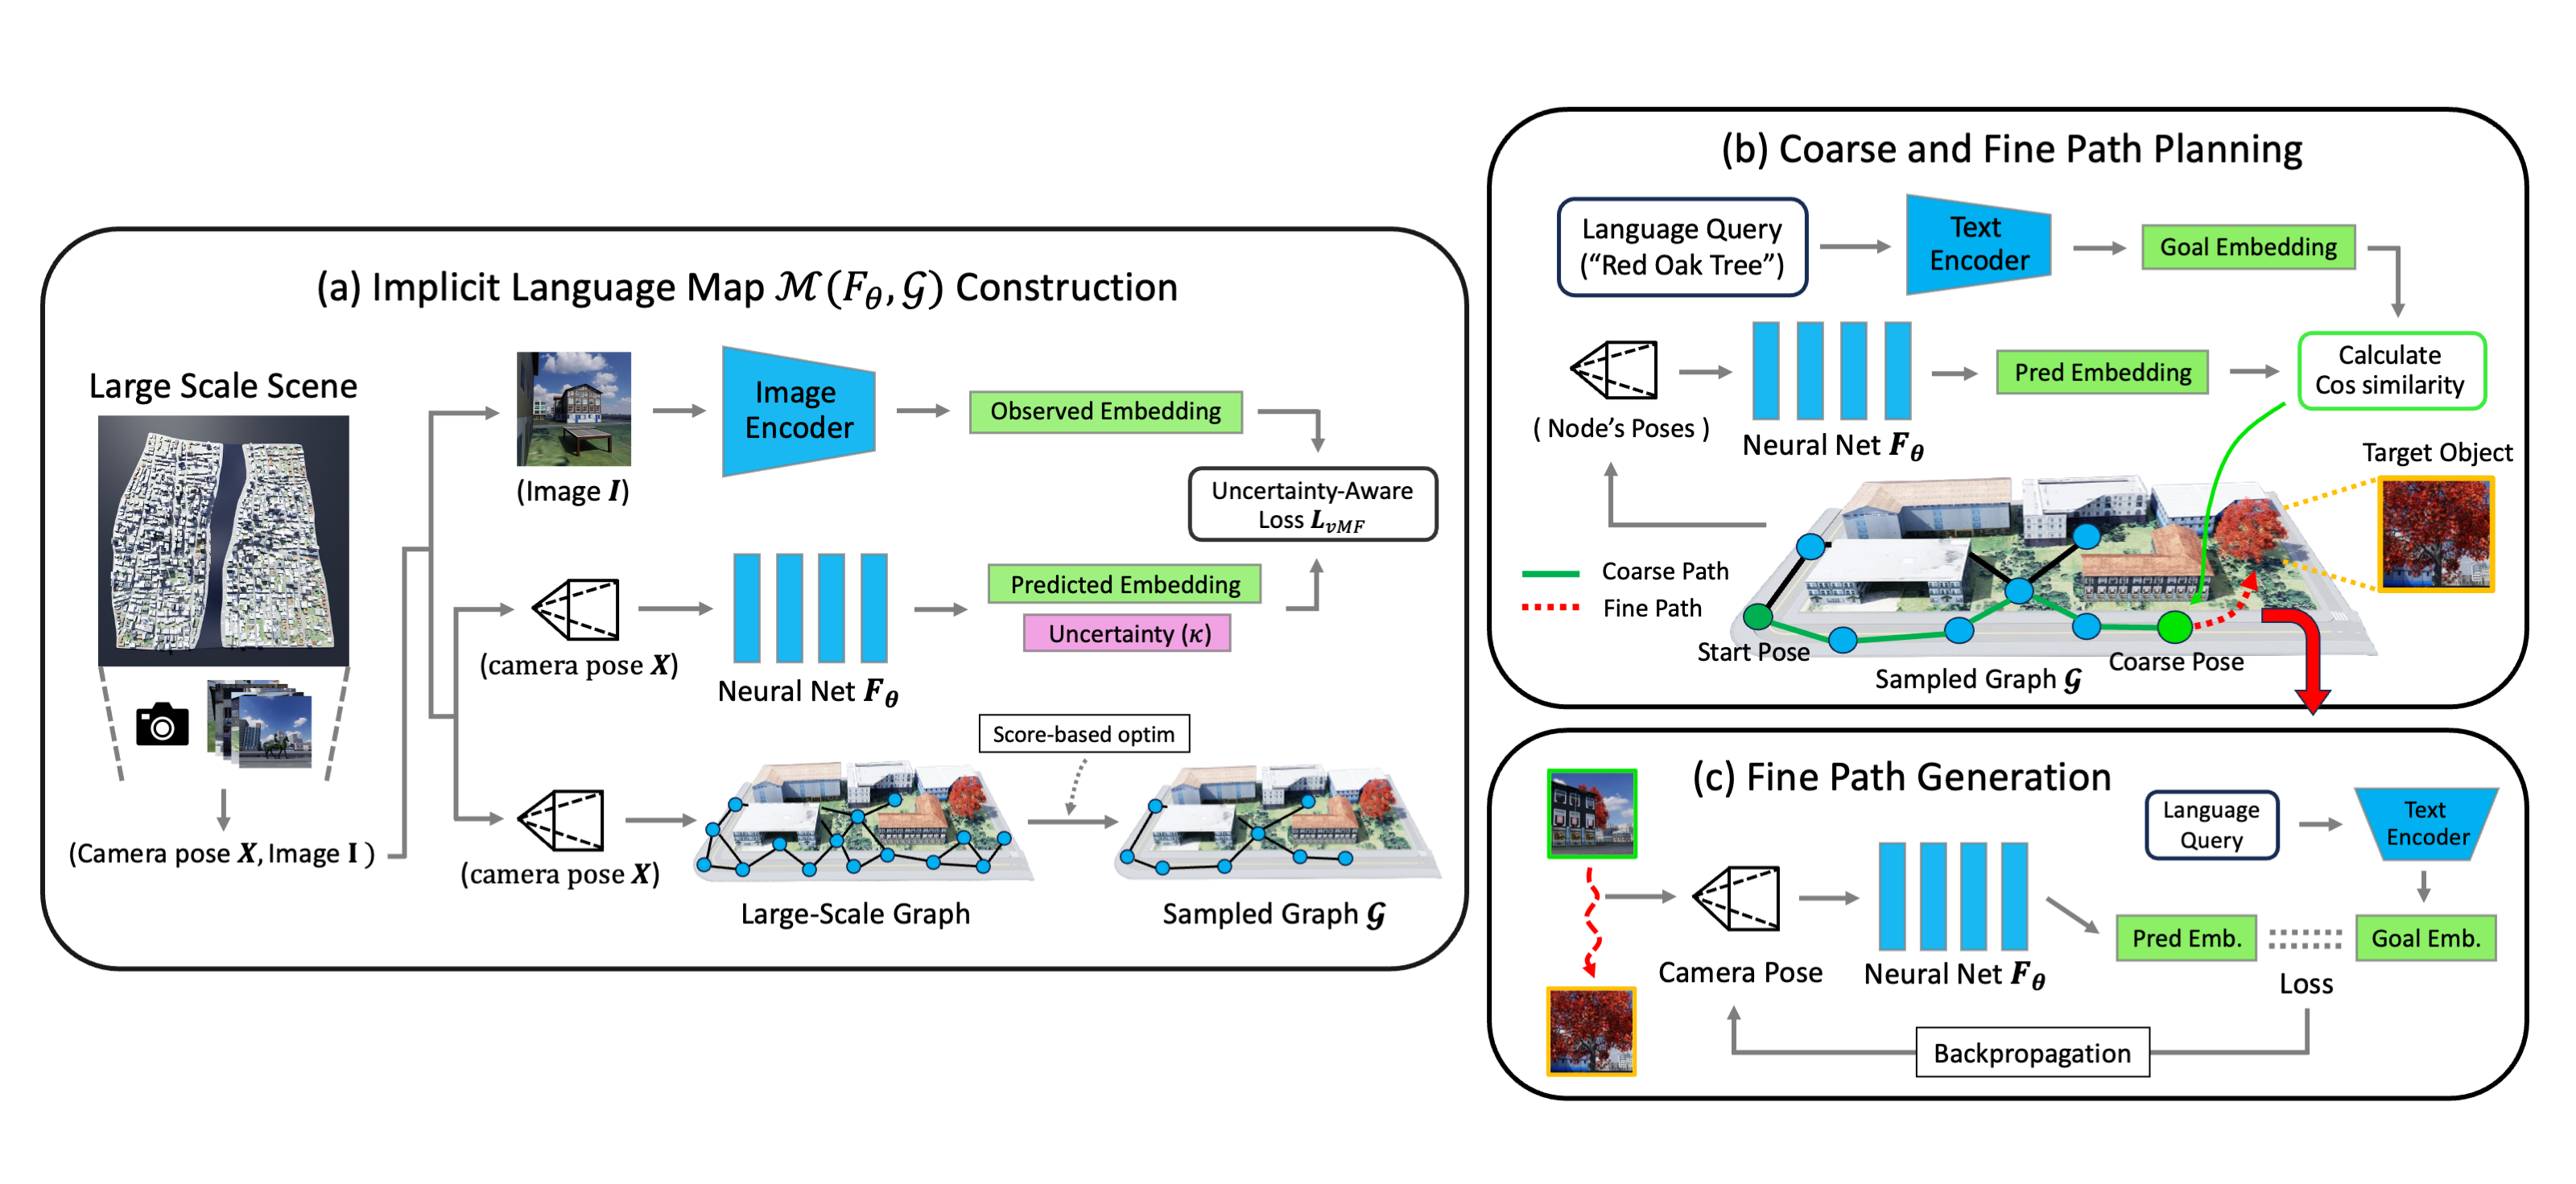
| Sep 2025 | 🎉 Our paper “LAMP: Implicit Language Map for Robot Navigation” is accepted to RA-L 2025. |
| Aug 2025 | 🏆 Honored to receive the LG AI Research Best Paper Award at the Conference on Korean Artificial Intelligence Association (CKAIA) 2025. |
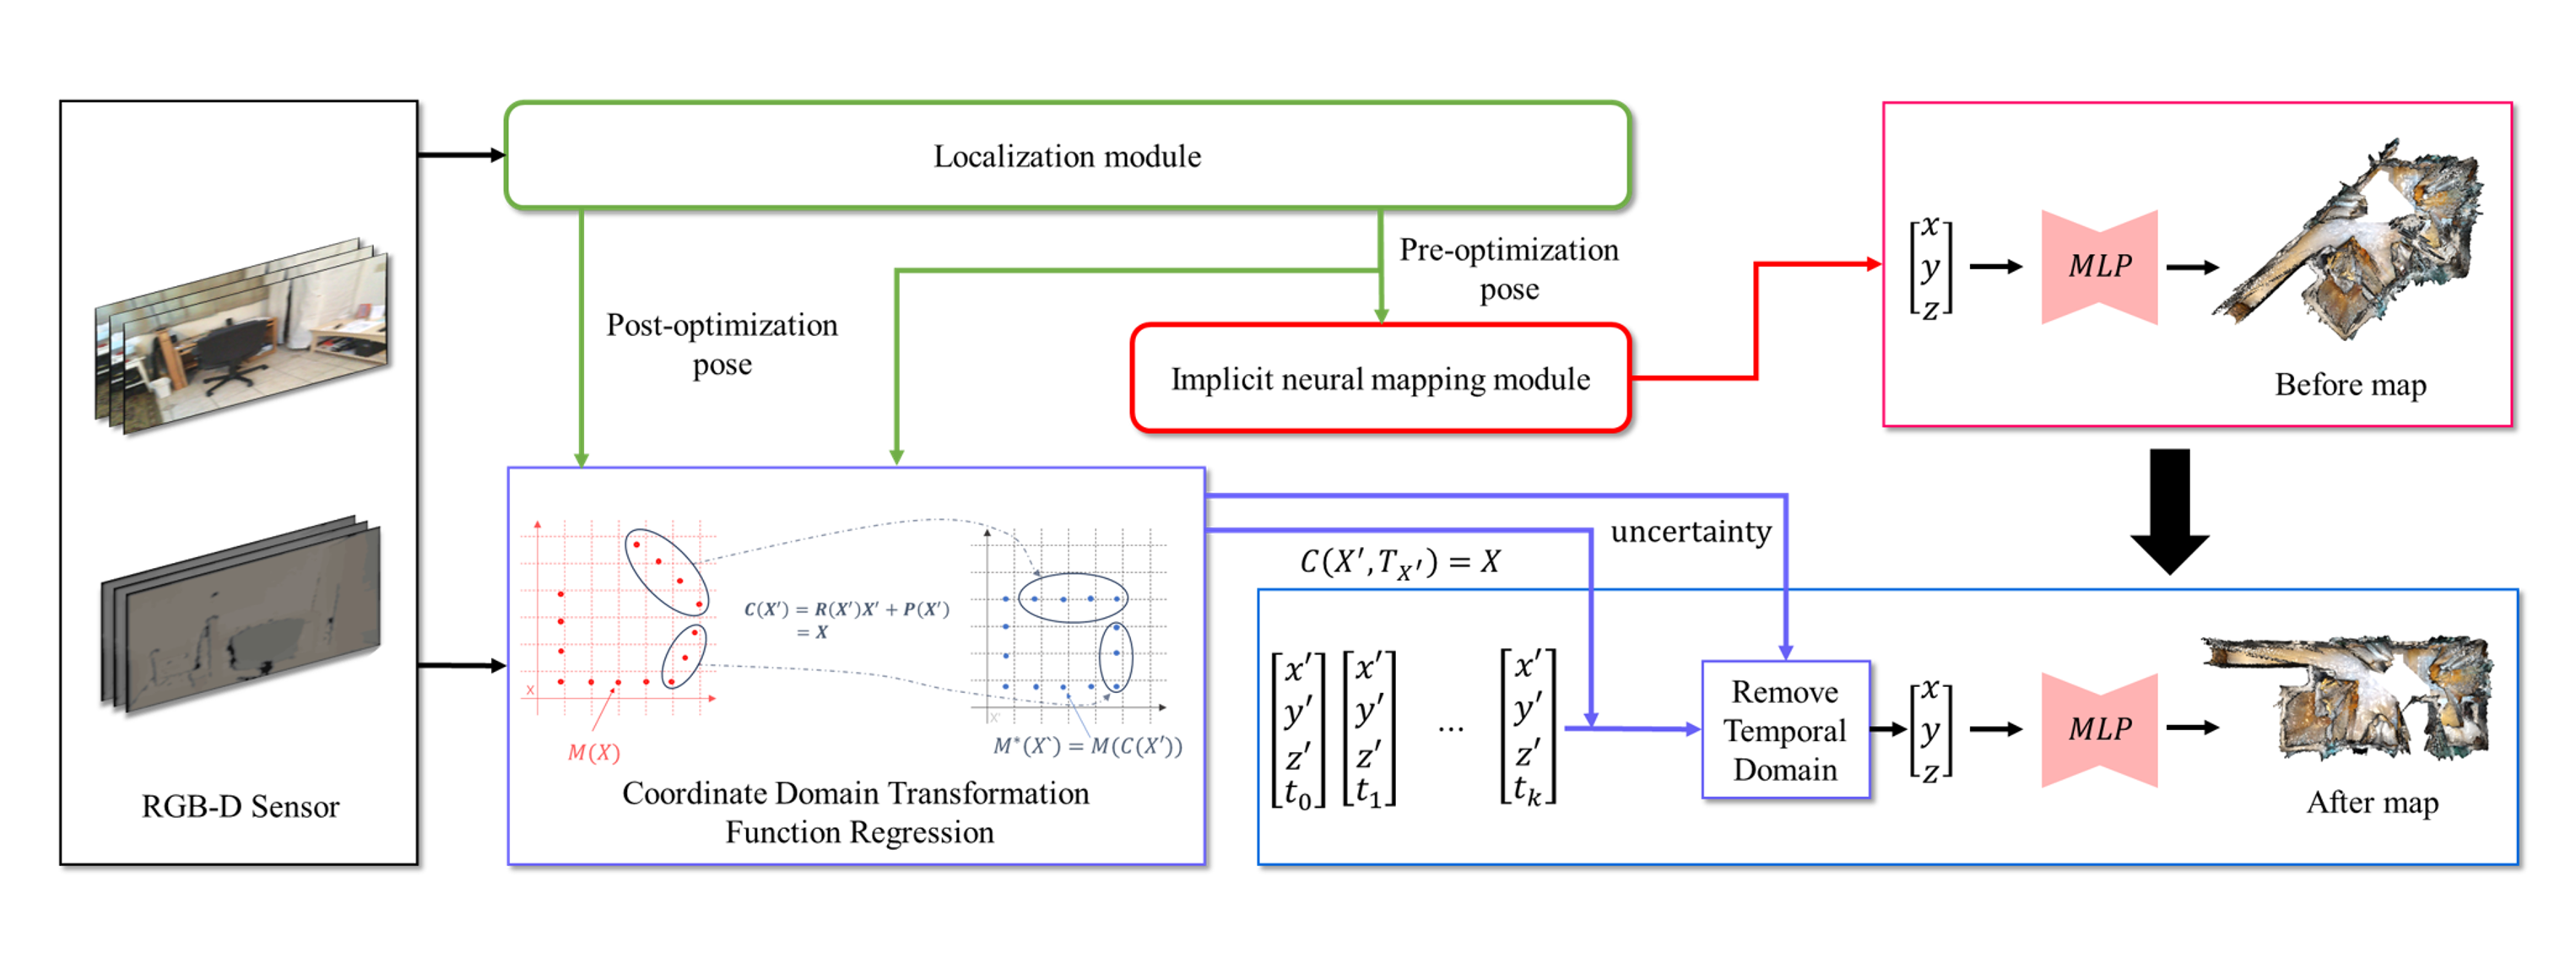
| Jul 2025 | 🎉 Our paper “Spatial Coordinate Transformation for 3D Neural Implicit Mapping” is accepted to RA-L 2025. |
| Jan 2025 | 🎉 Our paper “Bayesian NeRF: Quantifying Uncertainty With Volume Density for Neural Implicit Fields” is accepted to RA-L 2025. |
| Aug 2024 | 🏢 Joined Naver LABS (Vision Group) as a 3D Vision & Deep Learning Research Intern. |
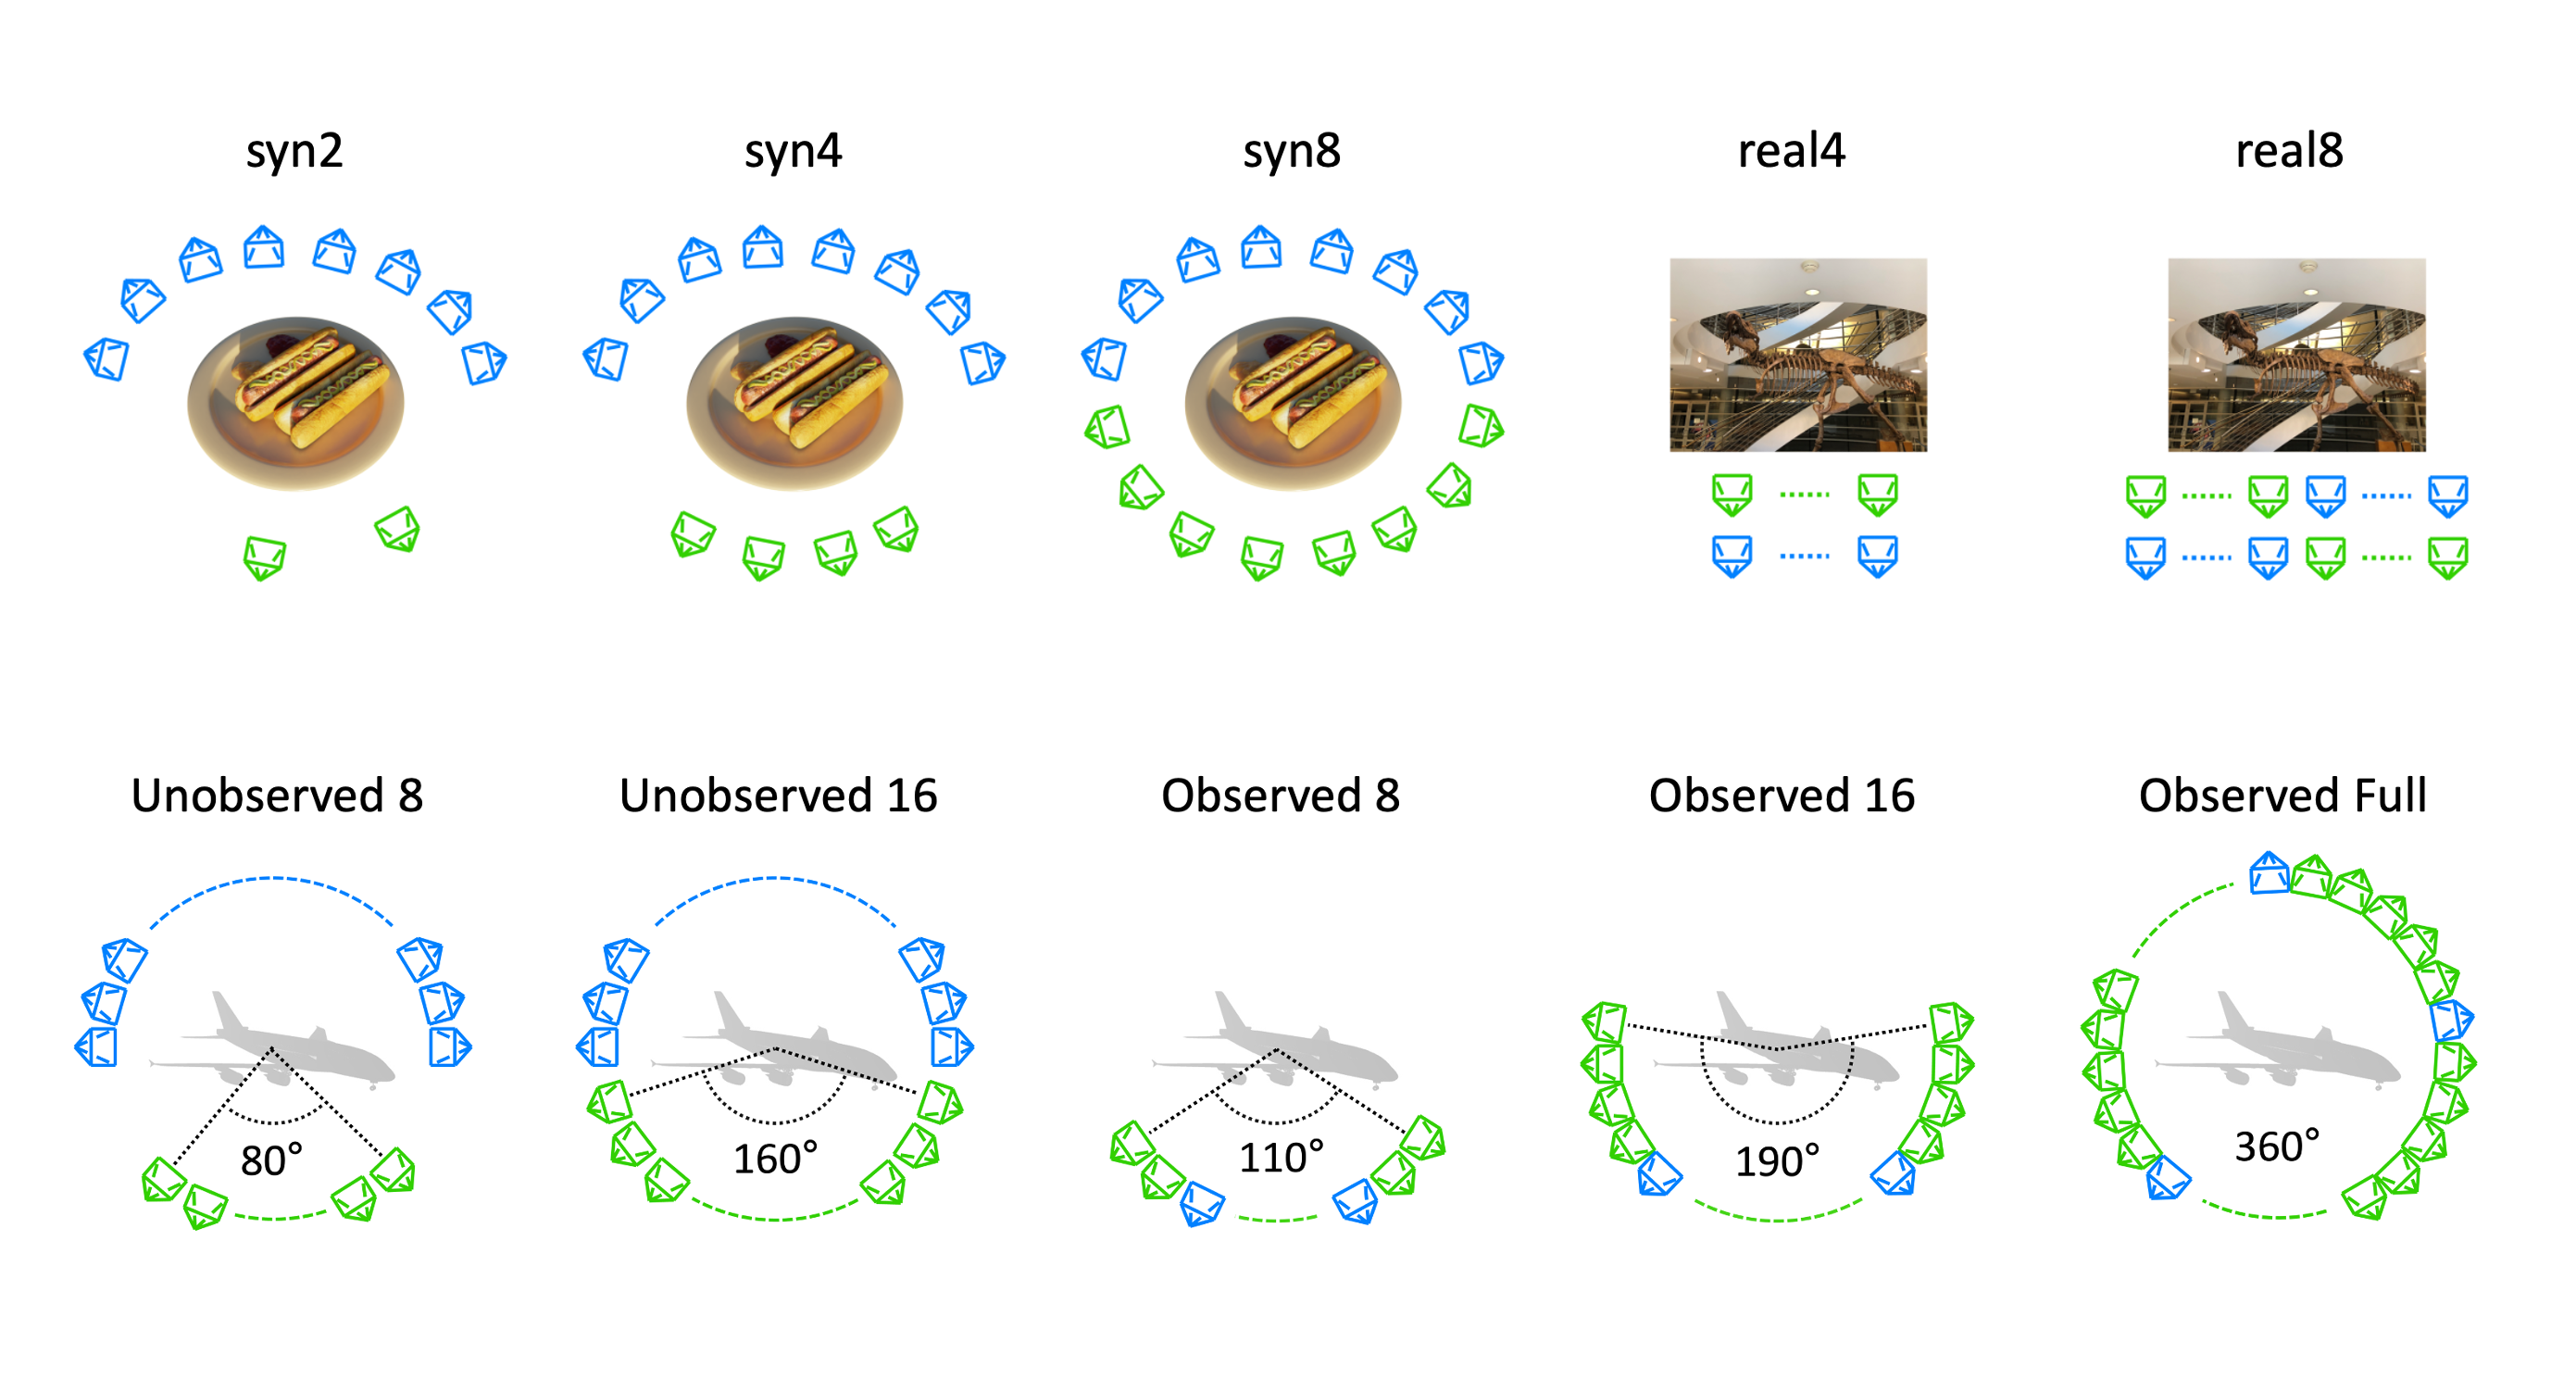
| Jun 2024 | 🎉 Our paper “Just flip: Flipped observation generation and optimization for neural radiance fields to cover unobserved view” is accepted to IROS 2024. |
Selected Publications
Show all NeRF 3D Representation Bayesian Learning Vision Language Model Robot Navigation 3D Perception Embedded Systems Gaussian Process Scene Representation Loop Closing Place Recognition SLAM